
ECE 290 Seminar: “From Stochastic Planning to Safe and Resilient Autonomy: Learning and Control for Robotic Systems”
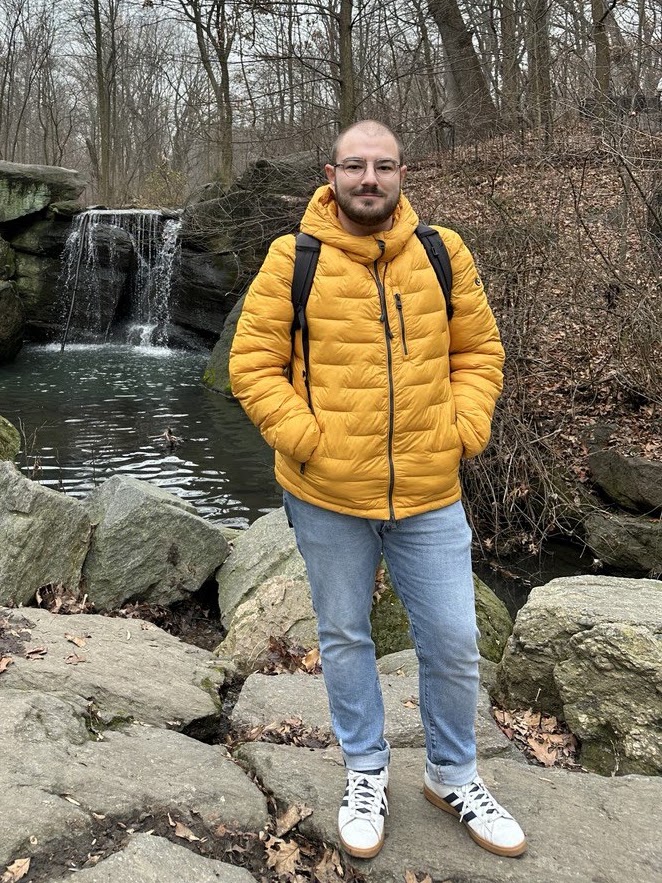
Presented by: Francesco Trotti, Marie Skłodowska-Curie Postdoctoral Fellow @ University of Bologna, Italy
Description: “Developing autonomous robotic systems capable of operating reliably in uncertain and dynamic environments requires the integration of planning, learning, and control while addressing fundamental challenges related to safety, robustness, and computational efficiency. This talk will present a research journey from stochastic optimal control and online decision-making to safety-critical learning and real-time robotic autonomy. First, I will discuss model-based planning methodologies based on Markov Decision Processes and Monte Carlo Tree Search, with applications to autonomous aircraft guidance, constrained optimal control, and decision-making under uncertainty. Building on these foundations, I will introduce recent advances in safe reinforcement learning, focusing on the integration of Control Barrier Functions with learning-based policies to improve safety and reduce unnecessary interventions. I will then address computational challenges in predictive safety and collision avoidance, highlighting approaches aimed at enabling efficient real-time operation.
Finally, I will introduce NEMORE, a Marie Skłodowska-Curie Postdoctoral Fellowship project investigating energy-aware and morphologically adaptive aerial systems. By integrating hybrid multi-mode control, regenerative actuation, and wind-adaptive autonomy, NEMORE aims to advance resilient and energy-efficient flight. The talk will conclude by discussing open research questions at the intersection of hybrid systems, optimization, learning, and control, toward autonomous aerial robots capable of adapting safely and efficiently to changing operating conditions.”
Bio: Francesco Trotti is a Marie Skłodowska-Curie Postdoctoral Fellow at the University of Bologna, Italy, currently conducting the outgoing phase of his fellowship at the University of California, Santa Cruz, under the supervision of Prof. Ricardo Sanfelice.
He received his Ph.D. in Computer Science from the University of Verona, Italy, in 2025, under the supervision of Profs. Riccardo Muradore and Alessandro Farinelli. During his doctoral studies, he was a visiting researcher at The Ohio State University, where he worked with Prof. Andrea Serrani on adaptive control.
His research interests include stochastic optimal control, autonomous planning, reinforcement learning, safety-critical control, and robotic systems. His current MSCA project, NEMORE, investigates hybrid control, energy-aware actuation, and adaptive autonomy for resilient aerial vehicles.
Hosted by: Professor Zhicong Yu & Professor Ricardo Sanfelice, Electrical & Computer Engineering Department
When: Monday, November 16th from 10:40 to 11:45 AM PST
Location: Classroom E2-194